OpenSim
OpenSim is a free, open-source platform for modeling and simulating movement and interaction among humans, animals, robots, and their environment.
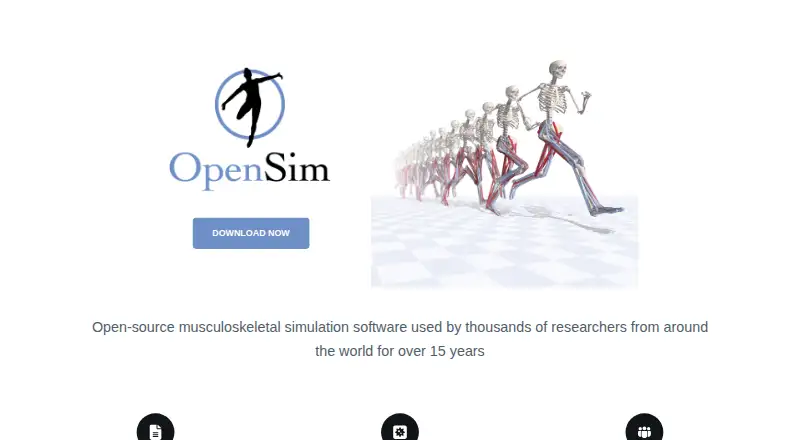
What OpenSim is
OpenSim is a free, open-source platform for modeling and simulating movement and interaction among humans, animals, robots, and their environment. Its graphical interface visualizes models and supports creating and analyzing simulations. Models can contain rigid bodies, joints, constraints, contact, muscles, and other actuators. Movement analysis tools include inverse kinematics, inverse dynamics, static optimization, and forward dynamics; Computed Muscle Control can generate muscle-driven forward simulations. The API can be used through Matlab, Python, Java, and C++, while GUI scripting uses an embedded Jython shell. Plugins can add analyses and model components, but must be built for the same OpenSim version and platform. The GUI is distributed for 64-bit Windows and Mac; there is no public Linux GUI distribution, though the API source can be built for Linux. OpenSim provides documentation, tutorials, and a discussion forum, and is intended for research and teaching as well as academic and commercial applications. Downloading requires a SimTK account.
Good
- Free and open source under Apache 2.0.
- Includes tools for movement analysis and simulation.
- API supports Matlab, Python, Java, and C++.
- Documentation, tutorials, and a discussion forum are available.
Watch out
- No public Linux GUI distribution is available.
- Plugins must match the OpenSim version and platform.
- Downloading requires a SimTK account.
Who it suits
OpenSim suits researchers and educators modeling movement or teaching related methods. Developers can use its API from several languages, while Linux users can build the API from source rather than use a public Linux GUI.
Verdict
OpenSim offers modeling and analysis tools for research, teaching, and other academic or commercial uses. Check the platform limitation and plugin compatibility requirements before adopting it.
Plans and prices
From OpenSim's own pricing page, checked 30 Sep 2026.
| Plan | Price | What it gives you |
|---|---|---|
| OpenSim | Free | Free and open-source software platform · download requires a SimTK account |
The facts
Each one read from OpenSim's own pages, with the date it was checked.
What it does
- 3D visuals
- Yeschecked 21 Sep 2026
- Audience
- The project describes OpenSim as suitable for research and teaching and welcomes academic and commercial applications.checked 30 Sep 2026
- Authoring tools
- Yeschecked 21 Sep 2026
- Data export
- Yeschecked 21 Sep 2026
- Data import
- OpenSim 4.0 added support for reading marker and force data in C3D files.checked 30 Sep 2026
- Delivery mode
- desktopchecked 21 Sep 2026
- Extensibility
- Plugins can add analyses and model components, but must be built for the same OpenSim version and platform.checked 30 Sep 2026
- Interface
- OpenSim includes a graphical interface for visualizing models and generating and analyzing simulations.checked 30 Sep 2026
- Lesson library
- Yeschecked 21 Sep 2026
- License
- The GUI and API are open source under Apache 2.0, while models, examples, and plugins may have their own licenses.checked 30 Sep 2026
- Modeling
- Models can include rigid bodies, joints, constraints, contact, muscles, and other actuators.checked 30 Sep 2026
- Movement analysis
- OpenSim provides tools for inverse kinematics, inverse dynamics, static optimization, and forward dynamics.checked 30 Sep 2026
- Muscle simulations
- Computed Muscle Control can generate muscle-driven forward simulations of movement.checked 30 Sep 2026
- Purpose
- OpenSim models humans, animals, robots, and the environment, and simulates their interaction and movement.checked 30 Sep 2026
- Scripting
- The API can be used through Matlab, Python, Java, and C++, while GUI scripting uses an embedded Jython shell.checked 30 Sep 2026
- Security
- The pages reviewed describe OpenSim's software licenses but do not state security certifications or compliance programs.checked 30 Sep 2026
- Support
- OpenSim provides documentation, tutorials, and a discussion forum where users can seek help from experts.checked 30 Sep 2026
- Supported systems
- The GUI is distributed for 64-bit Windows and Mac; the documentation says there is no public Linux GUI distribution.checked 30 Sep 2026
Money
- Free plan
- Yeschecked 21 Sep 2026
Where it runs
- Linux API
- The API source can be built for Windows, Mac, and Linux.checked 30 Sep 2026
The full review of OpenSim
Overview
OpenSim is an open-source platform for modeling and analyzing movement in humans, animals, robots, and their environments. It is best suited to researchers and educators who need to build and study biomechanical or other movement models. Its breadth of analysis tools and zero price are compelling, but the graphical interface is limited to Windows and Mac, and plugins must match the installed version and platform.
Key features
Build and inspect models
OpenSim's graphical interface visualizes models and helps users generate and analyze simulations. Models can combine rigid bodies, joints, constraints, contact, muscles, and other actuators, giving movement-focused work room to represent both structure and forces. The 3D visuals support inspection, while data export helps carry results into other workflows.
Analyze movement
Tools for inverse kinematics, inverse dynamics, static optimization, and forward dynamics cover several stages of movement analysis. Computed Muscle Control can produce muscle-driven forward simulations. Together, these capabilities make OpenSim more than a model viewer, though they are most relevant to users whose work depends on movement mechanics.
Automate and extend
The API can be used from Matlab, Python, Java, and C++; GUI scripting is available through an embedded Jython shell. Plugins can add analyses and model components, but must be built for the same OpenSim version and platform. That requirement can constrain shared or changing workflows. OpenSim 4.0 added the ability to read marker and force data in C3D files.
Teaching resources and licensing
A lesson library and authoring tools broaden its use in teaching. Documentation, tutorials, and a discussion forum where users can seek expert help offer practical support. The GUI and API use Apache 2.0, but models, examples, and plugins may have different licenses, so check those components individually before reuse.
Pricing
OpenSim is free and open-source software. The OpenSim plan costs free; there is no free trial because the software itself is free. Downloading it requires a SimTK account. There are no paid tiers or seat and usage caps stated for the plan, making it a straightforward choice when a free research or teaching platform fits the job.
Platforms
The desktop GUI is distributed for 64-bit Windows and Mac, not Linux. Linux users can build the API from source, as can users targeting Windows or Mac, but that is not equivalent to a public Linux GUI distribution. This distinction matters: choose OpenSim on Linux if an API-based workflow is suitable, not if you need the supplied graphical interface.
Who it's for
OpenSim is a strong fit for academic and commercial users studying movement who need configurable models, analysis methods, scripting, and teaching materials without a software license fee. It is a weaker fit for users seeking a Linux GUI or a plug-in workflow that cannot accommodate version- and platform-specific builds. The project describes security licenses, but provides no security certification or compliance program.
Pros and cons
Pros
- Broad movement-analysis toolkit: inverse and forward dynamics, inverse kinematics, static optimization, and muscle-driven simulation support varied research questions.
- Flexible automation: API access through four languages and embedded Jython scripting can suit both scripted and GUI-centered workflows.
- No software charge: the free, open-source GUI and API lower the cost of adopting it for research or teaching.
- Teaching support: lesson library, authoring tools, tutorials, and documentation serve instruction as well as analysis.
Cons
- No public Linux GUI: Linux use requires building the API from source, which rules out the supplied desktop interface.
- Plugin compatibility is narrow: extensions must match both OpenSim version and platform.
- Download account required: obtaining the software requires a SimTK account.
- Component licenses can differ: models, examples, and plugins may not share the GUI and API's Apache 2.0 license.
Alternatives
For other options in the category, browse Physics Simulation Software.
- SimFlow is worth considering for a freemium option with a free plan and trial across Linux, Mac, web, and Windows.
- SimScale may suit browser-based testing and learning: its Community plan includes selected analysis types, 10 unrestricted simulations, and up to 3,000 core hours.
- FeenoX is another free option for Linux-oriented or self-hosted workflows, with an API and web platform; it has no graphical interface.
- COMSOL Multiphysics is an alternative for users considering paid software with a free trial and Windows, Mac, Linux, web, self-hosted, and API platforms; its license is by quotation.
- OpenFOAM is a free alternative for Windows, Mac, and Linux.
- Xcos is free, open-source software distributed with Scilab for Windows, Mac, and Linux.
- myPhysicsLab offers free browser simulations, Apache 2.0 source code, and downloadable offline versions.
- Open Source Physics is a free alternative available on web, desktop, and mobile platforms.
Verdict
Choose OpenSim if your research or teaching centers on movement and you want a free, extensible toolkit for building models and analyzing their dynamics. Its most important trade-off is platform fit: Windows and Mac users get the GUI, while Linux users must work through the API source. If that limitation and the plugin compatibility requirements fit your workflow, OpenSim is a capable choice; otherwise, look to an option whose platform and workflow match your needs.
Getting started
- Visit the OpenSim website.
- Create a SimTK account to download the software.
- Choose the 64-bit Windows or Mac graphical interface, or build the API source for Windows, Mac, or Linux.
- Use the graphical interface or connect to the API through Matlab, Python, Java, or C++.
- Consult the documentation and tutorials, or seek help in the discussion forum.
Questions
Does OpenSim cost anything?
OpenSim is free and open-source. Its listed plan costs nothing.
Which operating systems are supported?
The GUI is distributed for 64-bit Windows and Mac, with no public Linux GUI distribution. The API source can be built for Windows, Mac, and Linux.
Which programming languages can use the API?
The API can be used through Matlab, Python, Java, and C++. GUI scripting uses an embedded Jython shell.
What can OpenSim model and analyze?
Models can include rigid bodies, joints, constraints, contact, muscles, and other actuators. Analysis tools include inverse kinematics, inverse dynamics, static optimization, and forward dynamics.
Is OpenSim open source?
The GUI and API are open source under Apache 2.0. Models, examples, and plugins may have their own licenses.
Who is OpenSim intended for?
The project describes it as suitable for research and teaching and welcomes academic and commercial applications.
Alternatives to OpenSim
- 1
SimFlow
Free planWebLinuxmacOSWindows8.2From €8,000 a year - 2

COMSOL Multiphysics
WebAPILinuxmacOS7.7 - 3
FeenoX
Free planWebAPILinuxSelf-hosted7.5Free plan - 4
myPhysicsLab
Free planWebLinuxmacOSSelf-hosted7.5Free plan - 5
OpenFOAM
Free planLinuxmacOSSelf-hostedWindows7.3Free plan - 6
MPTRAC
Free planWebLinuxSelf-hosted7.2Free plan